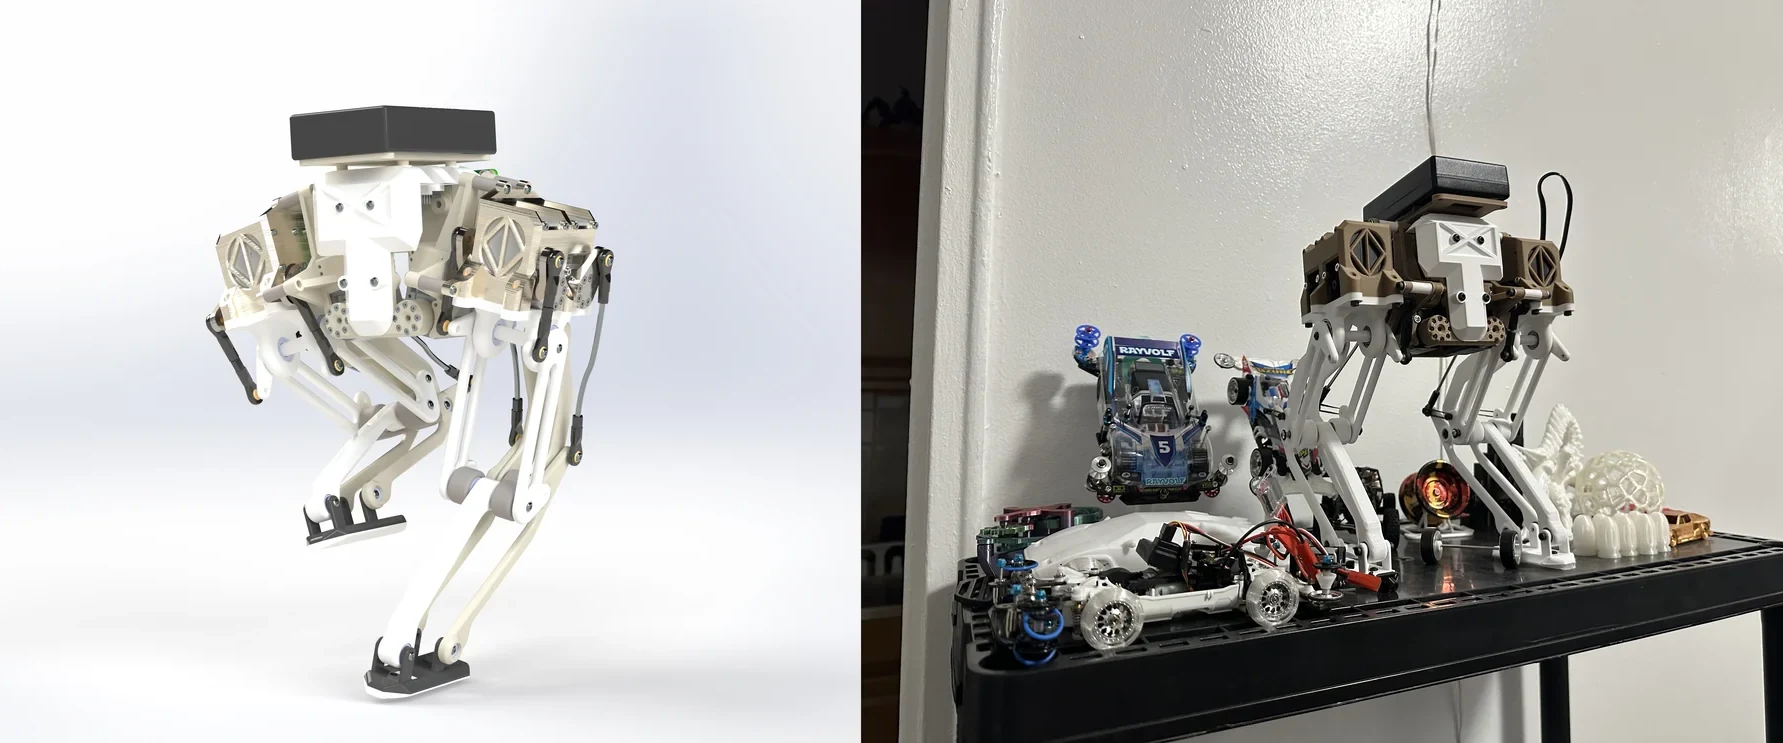
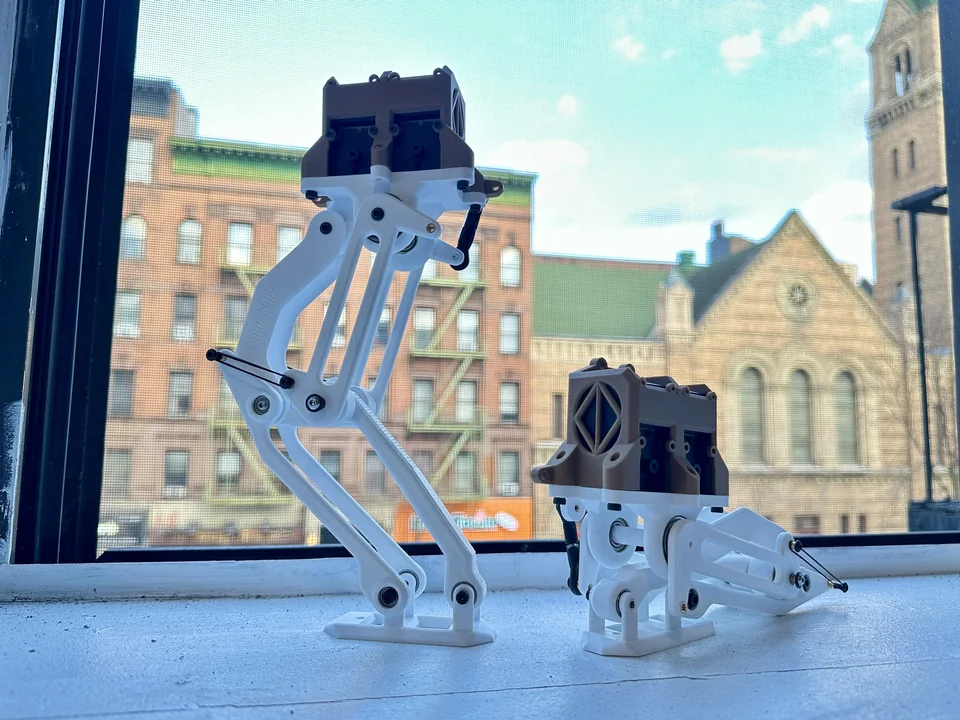
M.E.H is a bipedal robot built from nothing for MECEE4611 Robotics Studio, Spring 2025, with Zizai Ma under Prof. Hod Lipson. Custom mechanical design, embedded hardware, and a motion controller that had to work within both.
It walks at about 32 cm/s on flat ground — on lightweight parts and cheap actuators, which is the constraint that made the controller interesting.
Zizai led mechanical design, fabrication and hardware integration. I took the control side: gait planning, inverse kinematics, and the software architecture tying them together.
Legs and inverse kinematics
The leg linkage sets what the controller can ask for. Solving its inverse kinematics gives the joint angles for a desired foot position, and the reachable workspace tells the gait planner where it is allowed to put a foot down.
Walking
Iterating between gait parameters and what the hardware would tolerate is most of what turned a standing frame into a walking one. Low-cost actuators have backlash and limited torque, so the gait had to stay inside what they could actually deliver rather than what a simulator would allow.
My contribution
Control algorithms, gait planning, the inverse-kinematics solver, and the overall software architecture.